PenBot Mini is a credit-card-sized drawing robot that moves a pen using linked arms. Creator Dorian Todd originally began the project with the goal of building a robot to sign a senior yearbook. Along the way, a toaster-sized version drew more than 50 vector portraits of visitors at a 2025 event.
Shrinking the mechanism made even tiny motor inaccuracies visible on paper, so Todd added miniature bearings to its joints and software that calculates and corrects the pen's position.
It started with signing a yearbook, detoured through a portrait-drawing robot, and ended up as a pocket-sized precision machine. That's a long route to a signature.
A mini fridge mounted on tank treads can follow a person or run away from them. Designed for speeds above 15 mph, the robot uses autonomous navigation, human position tracking and behavior switching.
Creator Dorian Todd integrated a ROS 2-based control and perception system, working through a series of firmware and sensor-processing problems.
A fridge that comes to you is convenient. A fridge that can flee with your drinks is something else.
A maker added a linkage and rubber bands to make a Mini 4WD car jump. The first version held its legs in place with a cable tie, which had to be cut with nippers to release the jump.
A second version introduced remote-controlled release and achieved more stable jumps, but increasing the number of rubber bands to 32 dislodged a press-fit axle. Jumping while driving remains a goal for the next version.
The shortcut over the track has become a project in figuring out how to jump at all.
Gopher, a smaller version of the Australian WomBot robot originally developed to explore wombat burrows, has been deployed in eastern Türkiye. It is helping investigate a geological formation that some people believe could be connected to the biblical Noah's Ark.
Designed by La Trobe University's Robert Ross, the remotely controlled robot carries waterproof wide-angle cameras at both ends and environmental sensors. It can collect information from inaccessible spaces as far as 25 meters below the surface. The site's proposed connection to Noah's Ark remains disputed; no ark has been confirmed.
A robot built for wombat burrows has been reassigned to a biblical mystery. Quite a career change.
A glove-controlled tracked robot responds to a raised middle finger by raising its own mechanical finger. The maker says the build uses two Arduino Nano boards, a motion sensor in the glove, four drive motors and a servo for the finger.
The project was shared in a maker's Reddit post.
A remote-controlled robot with a very specific talent: outsourcing your rude gestures.
A team including sousci is developing an oversized mechanical finger designed to deliver powerful finger flicks. The project uses a large mechanism to amplify a simple flick.
The work-in-progress device is documented on ProtoPedia and uses components including Arduino hardware and servo motors.
To make a finger flick more powerful, they built an enormous mechanical finger. That's a lot of hardware for a single flick.
Runaway is a two-wheeled alarm robot. You set it from a phone but must catch it and press its button to stop it. Students who kept missing their 9 a.m. classes built it with an ultrasonic obstacle sensor.
Silencing your alarm now starts with chasing it around the room.
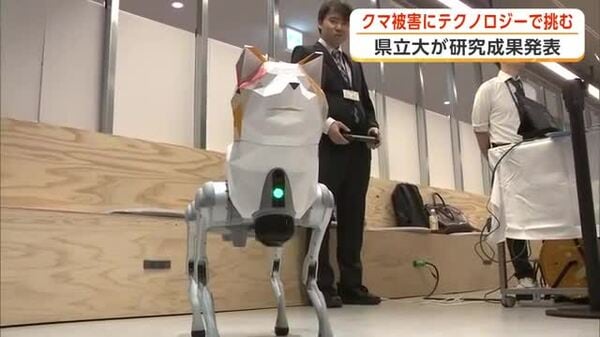
Hacchan, a four-legged robot with an Akita dog face, was presented as a prototype for deterring bears. It makes lifelike dog-barking sounds. The researchers aim to have the robots patrol buffer zones and gather in groups to drive bears away when one is spotted.
The team at Akita Prefectural University presented the project on October 13. They are developing an AI-based system intended to respond to bear movements without direct human control.
Its face looks like a dog from an old low-polygon video game, while the rest of its body is exposed machinery. The humans may be startled before the bears are.
A team taped a funnel to the end of a robot arm in an attempt to make it juggle. Their plan was to throw a ball upward and catch it in the same spot, alternating between two balls. Rather than use a camera to track the balls, they planned to repeat the same throw and catch motion.
Mandy Meindersma and two teammates worked on the idea at a September 2026 hackathon. They report that it was much harder than expected.
At the end of a precision robot arm is a funnel held on with tape. That's an unexpectedly charming meeting of industrial robotics and kitchen hardware.
Meshbot was built to carry a Meshtastic radio up a steel drainpipe on an apartment building. Nearby buildings made radio reception poor, and its creator couldn't access the roof to put an antenna higher up.
Robert Wallhead made a modular climbing robot using magnets and 3D-printable chassis parts. He describes the results as working reasonably well, while acknowledging it was hardly the most practical solution.
He couldn't get to the roof to improve radio reception, so he built a robot to climb the drainpipe instead. A signal problem turned into a robot expedition.
Sherobo looks like a round watermelon, then unfolds four legs and walks. It was designed around the Japanese watermelon-splitting game, with a watermelon-shaped robot that can flee on foot rather than sit still for a hit.
Creator Ryota Kobayashi built the 12-degree-of-freedom quadruped with a folding linkage mechanism that lets it return to a spherical shape. The project page includes build instructions and pictures of the transformation.
The watermelon in a watermelon-splitting game is finally able to run away. It seems the fruit has decided to participate on its own terms.
X-Mule is an online game in which browser controls move a physical rover around a Mars-themed set. Rather than using a simulated world, actions such as charging and moving cargo take place with real robots and physical objects.
Players control the hardware over the internet and carry out missions inside a physically built arena.
Instead of making a simulated game world look more realistic, this project simply builds the game world out of real objects. There is an actual robot waiting on the far side of your browser controls.











It started with signing a yearbook, detoured through a portrait-drawing robot, and ended up as a pocket-sized precision machine. That's a long route to a signature.